Mechanical Engineering Robotics Product Design

I design
that solve real-world problems.

I’m Paarth, a CMU Mechanical Engineering and Robotics student working across aerospace, robotics, embedded systems, and AI-enabled products.

Explore all projects ↗
01 DEFINE02 MODEL03 BUILD04 MEASURE05 ITERATE
Selected work / 06

Evidence over adjectives.

Each project traces a decision from constraint to built or shipped result.

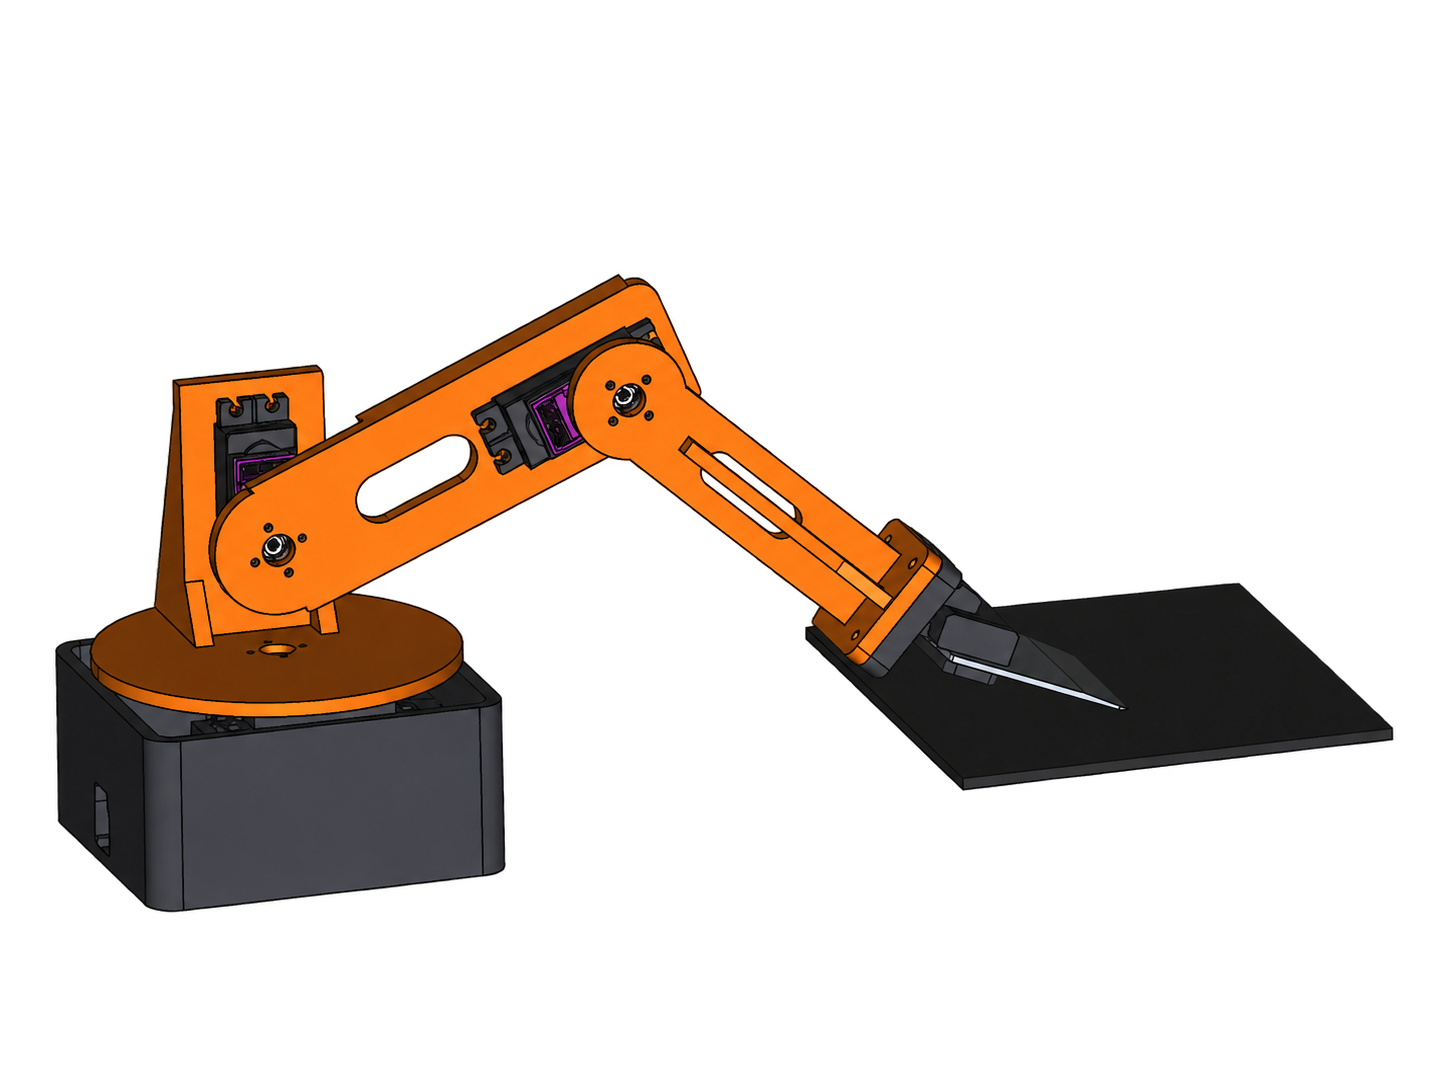
Transparent CAD view of the full robot arm with scraper11
robotics · productBuilt + end-effector tested

3-DOF 3D Printed Robot Arm

A printed servo arm for removing prints from a printer bed, developed through torque analysis, kinematic visualization, and task-specific end effectors.

3degrees of freedom195 mmlinkage reach72 gmodeled gripper payload
View full project ↗
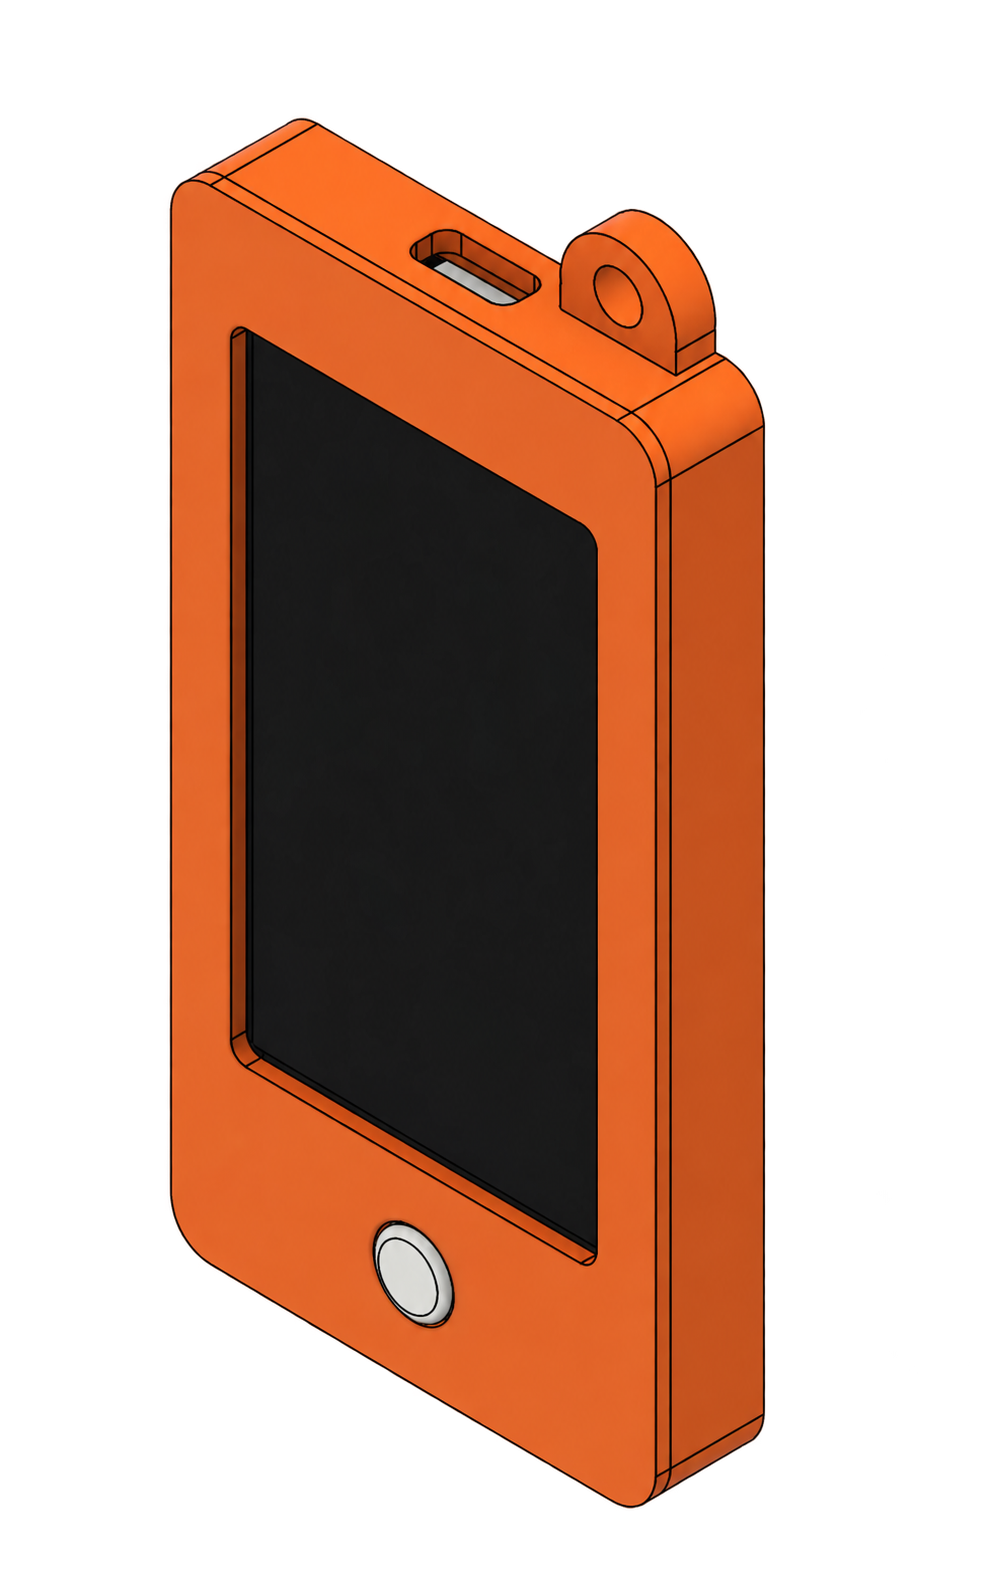
Isometric CAD view of an orange pocket-sized handheld AI module with display, button, and attachment loop.06
wearables · ai · productAssembled prototype

Handheld AI Module

An assembled ESP32-based handheld device that brings notifications and human approval into a physical interface away from a laptop.

2–3 intarget height~2 indisplay500 mAhbattery
View full project ↗
Complete project archive10 projects ↗

The disciplines change.
The method does not.

Whether the system flies, moves, sits on the body, or lives in software, I start by turning ambiguity into testable constraints.

  1. DefineTranslate the problem into requirements and success criteria.
  2. ModelUse physics, geometry, simulation, or architecture to narrow the space.
  3. BuildMove beyond diagrams into integrated hardware or a functioning product.
  4. MeasureCollect flight data, wear feedback, sensor output, or product evidence.
  5. IterateChange the design when the evidence says the first answer is wrong.

A systems-oriented engineer who likes the whole loop.

I’m a sophomore at Carnegie Mellon studying Mechanical Engineering with an additional major in Robotics. I’m most interested in the overlap between mechanical design, intelligent systems, and products people can actually use.

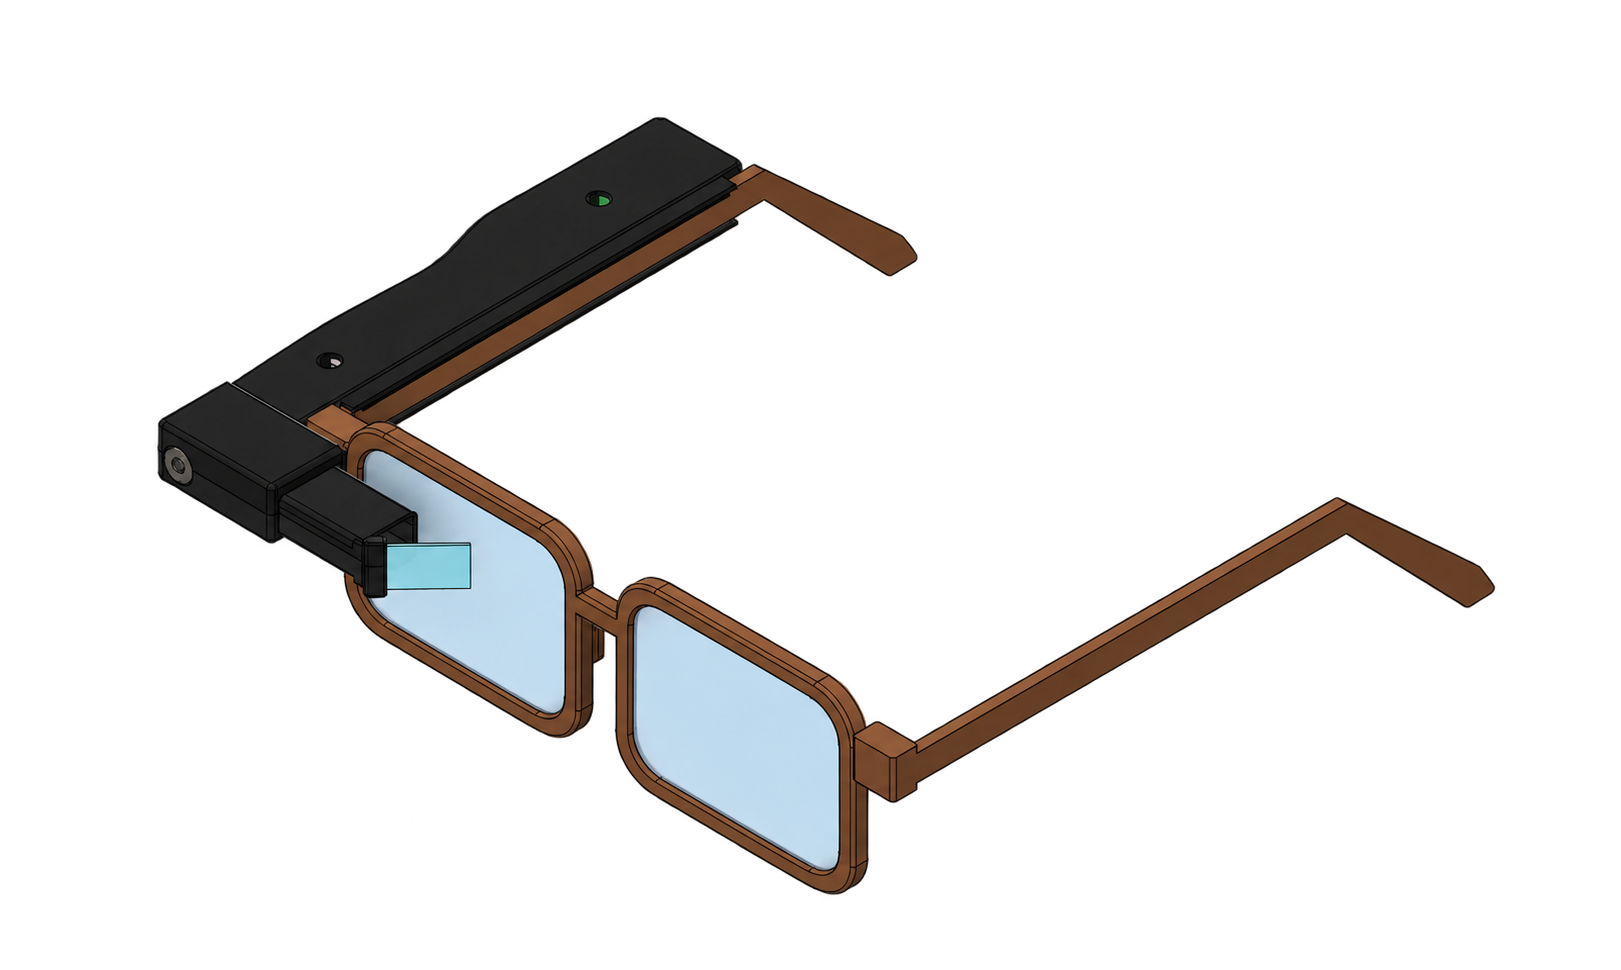
My projects have moved from competition robotics and LiDAR research to a 3D-printed aircraft, wearable optics, robotic EV charging, mobile apps, and autonomous agents. The connective tissue is ownership: understanding why a system should exist, choosing its architecture, and carrying it through build and test.

CMUCarnegie Institute of Technology2028Expected graduation3.75GPA / 4.00